

On this page
- 01Before you start
- 02Where it sits in the project
- 03The four pillars
- 04How they work together
- 05PLC hardware, I/O and programming
- 06VFDs and electromagnetic interference
- 07Industrial protocols and networks
- 08SCADA servers, history and availability
- 09Specifications that actually matter
- 10Pre-sales: sizing, I/O rules and BOQ
- 11Installation, FAT, SAT and commissioning
- 12Check that it works
- 13Common problems and how to fix them
- 14Frequently asked questions
- 15Talk to PSS about automation
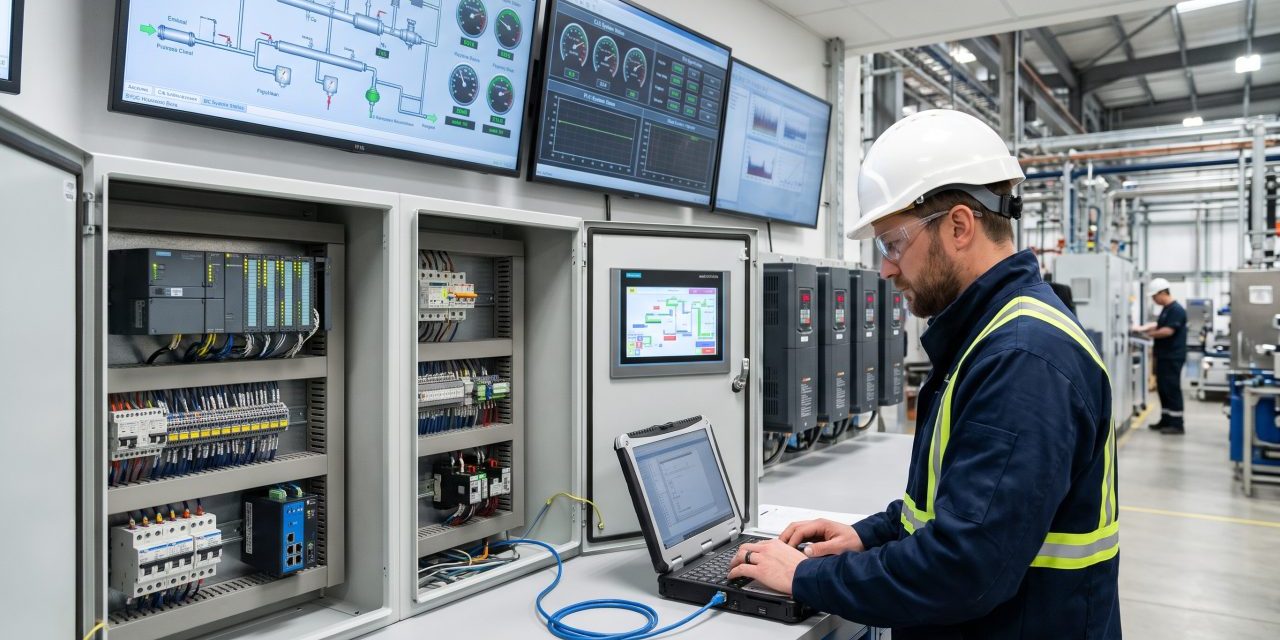
Industrial automation is the foundation of modern manufacturing, water and wastewater plants, oil and gas facilities, power generation, packaging lines and many other process applications. Sensors measure the process. Controllers execute programmed logic. Drives regulate motors. Operator interfaces give local visibility. Supervisory systems collect data, manage alarms and oversee the facility.
Four essential components form the core:
- PLC (Programmable Logic Controller) — executes control logic and coordinates machines and processes.
- HMI (Human-Machine Interface) — graphical interface for authorised monitoring and commands.
- Drives, especially VFDs — control speed and operation of compatible AC motors.
- SCADA (Supervisory Control and Data Acquisition) — supervisory monitoring, alarms, history and multi-device or multi-site visibility.
They work together, but each has a distinct role. The discipline is separation: logic in the PLC, presentation in the HMI and SCADA, and safety in hardware that depends on neither — a standard PLC is not automatically a safety-rated controller.
Bottled-water line example. Sensors detect bottles, tank levels and equipment state. The PLC runs the production sequence and commands motors and valves through suitable interfaces. VFDs regulate motor speed. The HMI shows local status and alarms. SCADA collects data from many machines for overall production, performance and history. Automation can improve consistency and visibility — it does not automatically guarantee energy savings, safety or higher productivity. Those depend on engineering, equipment, logic, commissioning and maintenance.
Before you start
- Process description with a P&ID or machine sequence — not only a verbal sketch.
- I/O list by type (DI/DO/AI/AO), networked device data and software tags, with contractual spare %.
- Centralised or distributed I/O and field distances; plant-mandated network (PROFINET, EtherNet/IP, Modbus, …).
- Safety-related functions and required SIL/PL; who owns SCADA servers (IT/OT boundary).
- Drives, motor efficiency class, harmonic filtering; loss-of-comms philosophy in writing.
- FAT/SAT scope; program handover; who maintains after year one with which spares and backups.
Where it sits in the project
ISA-95 (IEC 62264) numbers the layers — useful in meetings. Level 0 is the physical process. Level 1 is sensors and actuators. Level 2 is the PLC or DCS performing sub-second control. Level 3 is manufacturing operations — MES, the historian, and SCADA where it supervises rather than controls. Level 4 is ERP.
Most integration disputes are boundary disputes: who owns a start command, who owns a setpoint, and who may write to the other level. Settle that in the design phase, in writing.
The four pillars
PLC — the brain of the control system
An industrial controller built for electrical noise, vibration, temperature variation and continuous duty. Typical uses: packaging lines, pumps and compressors, conveyors, water/wastewater, ovens, material handling, machine tools and utilities.
Simplified scan cycle (exact behaviour depends on architecture): update inputs → execute user program → update outputs → communication and diagnostics. Some platforms add periodic tasks, event-driven execution or process-image updates.
Typical responsibilities: start/stop; sequences; interlocking and permissives; timers/counters; analog processing; PID where supported; drive communication; status and alarm detection; HMI/SCADA communication.
Pre-sales starts from the I/O list, process complexity, performance, interfaces and expansion. Site work verifies wiring, signal types, module config, faults and behaviour under normal and abnormal conditions.
Drives and VFDs
A VFD controls compatible AC motor speed by varying frequency (and voltage/parameters per its design). The PLC decides what the process needs; the VFD controls the motor within configured limits. Common loads: pumps, fans, blowers, compressors, conveyors, mixers.
Why a VFD? Continuous full-speed pumping can waste energy or overshoot pressure. Adjustable speed, controlled accel/decel, reduced starting stress, process regulation, motor monitoring and PLC/SCADA integration are typical benefits. Savings are application-dependent — large on suitable variable-torque pumps/fans; much less on many constant-torque conveyors. Fan and pump shaft power follows the cube of speed: at 80% speed, shaft power is about 51% (0.8³).
PLC ↔ VFD: hardwired (DO run, DI running/fault, AO speed reference, AI feedback) or network (commands, status, references, diagnostics). Document the method in the control design and I/O list.
Commissioning checks: motor nameplate V/I/kW, speed range, accel/decel, control and reference source, motor-control mode, overload/protection, cooling/environment, communication, cable/grounding, fault and restart behaviour — always per manufacturer and approved design.
HMI — the operator interface
Installed on a machine door, panel or station. Replaces or complements pushbuttons, lamps, selectors and meters. Functions: status and live values; authorised start/stop; approved setpoints; alarms and fault codes; modes; trends/diagnostics; permissions; recipes where applicable.
An HMI is commonly machine- or cell-scoped but may show multiple PLCs if the architecture allows. It sends requests; the PLC evaluates logic and permissives. It is not the primary control logic and not a substitute for required safety. Good HMI practice: clear critical data; consistent symbols/units; obvious abnormal states; little distraction; show comms failure and invalid data; restrict writes; show operating mode; support alarm investigation; follow site HMI philosophy (ISA-101 is a useful design/management reference). Size by tags and screens, not inches.
SCADA — supervisory monitoring and control
Collects data from dozens or hundreds of PLCs/RTUs. Functions: centralised monitoring; authorised supervisory commands; alarms/events; history and trends; reports/dashboards; comms status; run-hours and production tracking; multi-site supervision; approved higher-level data exchange.
HMI vs SCADA: HMI is typically local machine/unit; SCADA is broader visibility and retention. The boundary is not absolute — choose by device count, retention, alarms, architecture and operations.
Infrastructure: software, workstations, application/comms servers, historian, alarm services, networks, backup/recovery, redundancy where justified. A small app may run on a suitable industrial PC; a critical facility may need engineered redundancy. Size for vendor requirements, tags, logging rates, retention, users, availability and integration. Utility telemetry often uses DNP3 (IEEE 1815) and IEC 60870-5-104 with RTUs.
How they work together
Pumping-station sketch: Pressure transmitter → PLC → speed reference / run command → VFD → motor → pump → pipeline pressure changes → feedback to PLC. Local HMI: status, setpoints, alarms, commands. SCADA: supervisory monitoring, alarms, trends, history.
Real-time control normally stays in the PLC or designated local controller. HMI and SCADA provide operator and supervisory functions. Define that split in writing.
Golden rule: keep time-critical control local. If SCADA is down, the PLC should continue assigned functions when design permits. Do not assume that after every network failure: remote I/O, networked permissives or drives can stop the process. Define loss-of-comms behaviour — continue or stop, drive run retain or remove, stale-data handling, fallback outputs, alarms, recovery.
PLC hardware, I/O and programming
Hardware
| Component | Function |
|---|---|
| CPU / power supply | Execute program; supply required power |
| DI / DO / AI / AO modules | Discrete and analog field signals |
| Communication / remote I/O | Extra networks; distributed stations |
| Engineering interface | Configuration, programming, diagnostics |
Compact units integrate functions; large systems use modular racks and distributed I/O. Match I/O count, signal types, performance, expansion, environment and communications.
Digital and analog signals
DI examples: proximity, limit switch, motor auxiliary, level switch, valve feedback, selected faults. DO examples: relay/solenoid/contactor commands, lamps, enables. Account for voltage, current, isolation, commons and output type.
AI examples: pressure, temperature, flow, level transmitters (often 4–20 mA or 0–10 V). AO examples: VFD speed reference, modulating valve, actuator position.
Scaling example — 0–10 bar, linear 4–20 mA:
P (bar) = (I − 4) / 16 × 10
. At 12 mA → 5 bar. Also verify PLC raw-count conversion, engineering range, diagnostics and calibration.
PNP / NPN — sourcing and sinking
Symptom: sensor LED on, PLC input unchanged — often sensor/input mismatch. PNP typically sources +V when active; NPN typically sinks to 0 V. Common 24 VDC practice pairs PNP with sinking inputs and NPN with sourcing inputs — verify the module diagram, sensor datasheet and commons; labels alone are not enough. Checklist: supply; output type; module design; common wiring; measure at PLC terminal safely; confirm address and PLC status.
IEC 61131-3 languages
LD — ladder, familiar for discrete/relay-style logic. FBD — function blocks, often for analog/process. ST — text for calculations and data. SFC — steps and transitions for sequences. Use what the platform supports and the team can maintain.
VFDs and electromagnetic interference
VFDs switch at high frequency and can disturb nearby control circuits.
Possible symptoms: analog values jump when a motor starts; false sensor trips; unstable comms; unexpected PLC input edges; readings that track motor speed/load. Also investigate grounding, wiring, scaling, failed instruments and config — EMI is one cause among several.
Practical guidelines: separate power and signal routes; use manufacturer-specified motor and instrument cables; follow specified shield bonding (not one universal “ground one end” rule for every Ethernet/RS-485/instrument/VFD case); keep sensitive wiring away from noisy power parts in the cabinet; fix routing/termination/bonding before changing PLC filters or software scaling. Design EMC in engineering — do not leave it only as a commissioning patch.
Industrial protocols and networks
Supervisory updates may tolerate more delay than motion control. Design for the actual timing need.
| Network | Typical cycle / use | Identity / notes | Use when |
|---|---|---|---|
| PROFINET RT | ~1 ms typical | EtherType 0x8892 | Machine control in Siemens-based plants |
| PROFINET IRT | 250 µs min (31.25 µs special HW) | Scheduled slots; <1 µs jitter class | Synchronised motion — not a conveyor that needs 20 ms |
| Modbus RTU / TCP | 10–100 ms poll typical for TCP | RS-485 / TCP 502; register maps | Meters, drives, instruments, slow process data |
| EtherNet/IP | 1–10 ms (CIP Motion sub-ms) | TCP 44818 · UDP 2222 | Rockwell ecosystems, mixed I/O |
| OPC UA | Supervisory / higher-level exchange | Certificates, auth, endpoints | Historians, MES, analytics |
| CANopen | Machine / embedded | Device profiles | Selected machine applications |
A shared protocol name does not guarantee every function. For Modbus RTU check baud, parity, stop bits, address, A/B per datasheet, topology/termination. For TCP check IP, availability, registers, data types/word order, access rules.
Network hardware: industrial/managed switches, VLANs, fibre, media converters, redundant paths/PSUs, monitoring, industrial connectors. Match environment, topology, performance and resilience — not every plant needs the same switch class. An unmanaged switch in an undocumented ring is a decision to fail later.
SCADA servers, history and availability
A desktop PC may suit a small non-critical demo if it meets software requirements. Production systems often need industrial PCs or servers, separate app/DB services, UPS, tested backups — and sometimes redundant servers/paths. Enterprise hardware alone is not availability; architecture, monitoring, power, network and procedures matter.
Historians store measurements, status changes, alarms/events, production counts, energy and run hours. Plan tags × rate × retention × compression × growth. RAID ≠ backup.
Before specifying redundancy, define tolerated failures, recovery time, acceptable history loss, failover detection, synchronisation, return-to-normal and how failover is tested.
Specifications that actually matter
PLC: scan time vs real I/O; memory headroom; IEC 61131-3 languages; native remote I/O. HMI: tags, alarms, update rate, user management. Drives: efficiency and harmonics — EU Regulation 2019/1781 has required IE3 for many three-phase motors 0.75–1,000 kW since July 2021, and IE4 for 75–200 kW since July 2023; VSD losses capped at IE2 level. Safety (separate): IEC 61508 SIL 1–4; IEC 62061 SIL 1–3 for machinery; ISO 13849-1 PL a–e. A typical e-stop chain often lands around SIL 2 / PL d. OT security: IEC 62443 zones and conduits — no casual internet route onto the PLC network.
Pre-sales: sizing, I/O rules and BOQ
- Understand the process — function, capacity, equipment, instruments, sequences, modes, alarms/interlocks, existing interfaces, HMI/SCADA, safety/regulatory, expansion.
- I/O list — every physical signal as DI/DO/AI/AO; separate networked device data and software tags. Include tag, description, type, range, normal state, controller, units, method, tests.
- Count by type — e.g. illustrative 48 DI / 24 DO / 12 AI / 8 AO — then modules for channels, grouping, isolation, spare and availability.
- Rules of thumb: motor starter ~4–6 DI/DO points; hardwired VFD ~3 DI + 1–2 DO + 1 AI for speed ref; analog loop 1 AI (+1 AO if controlling); valve with feedback ~2 DI + 1 DO. Spare often 15–20% digital and 20–30% analog (planning range — not universal); round to 8/16/32 module sizes; size 24 VDC on real module load. Allow spare ports, cabinet space and power.
- CPU — performance, task complexity, scan/response, PID/motion, memory, ports, remote I/O, redundancy, tools, lifecycle. Few I/O can still need a powerful CPU for motion or high-speed comms.
- HMI / SCADA / network — screens, stations, tags, users, alarms, trends, retention, drivers; topology, ports, fibre, segmentation, environment, availability; licences.
- Drives and instruments — motor nameplate and load; instrument range, accuracy, signal, process connection, environment.
- BOQ buckets: PLC CPU/PSU; DI/DO/AI/AO and remote I/O; comms/gateways; HMI; SCADA software/licences; industrial PCs/servers; VFDs and accessories; sensors; panels/terminals/relays; switches; cables; programming; HMI/SCADA config; integration/test; FAT/SAT; commissioning/docs; training. State who supplies what.
Cost depends on more than terminal count: complexity, safety, motion, integration, graphics, panels, install, FAT/SAT, documentation and contingency. A small high-complexity cell can cost more per I/O than a large simple plant.
Installation, FAT, SAT and commissioning
Pre-commissioning: panel inspection, models vs drawings, point-to-point continuity, addressing, instrument mounting, drive cable/grounding, network links, program/licence versions, safe test windows.
Cold commissioning: energise control without process fluid/product where possible — verify I/O states, HMI navigation, simulated sequences, alarm presentation, comms.
Hot commissioning: real process — sequences, interlocks, PID tuning, VFD response, SCADA trends/alarms, loss-of-comms behaviour.
FAT catches design and software errors before shipment. SAT proves the installed system on site against the approved design. Document expected vs actual, deficiencies and retests. Hand over as-builts, final I/O lists, program backups with revision control, network addressing, parameter sets, test records, licences and training — transfer credentials securely.
Check that it works
- Every critical I/O point passes point-to-point with correct type, scaling and address.
- Sequences, interlocks and PID loops behave as written under cold then hot conditions.
- Local PLC continues assigned functions when SCADA is down, per the loss-of-comms design.
- VFD response, cable/grounding and EMI behaviour match the approved design.
- HMI and SCADA tags, alarms and trends are usable (no flood; meaningful delays).
- As-builts, program backups, licences and operator training are complete before handover.
Common problems and how to fix them
Sensor LED on, PLC input off
PNP/NPN mismatch, commons, voltage, wrong address.
Analog jumps when VFD starts
Routing, shielding/bonding, grounding, instrument health, scaling.
Modbus offline / wrong values
Serial params, address, polarity, topology; register map, signed/unsigned, scale, word order.
PROFINET / EtherNet/IP device missing
IP/name, topology, device role, GSDML/EDS, switch config.
Output commanded, plant silent
HOA Hand, interlock, module fault, wiring, field device. Never bypass a required safety interlock.
HMI shows stale data
Lost PLC link, wrong tag, update rate, server/client licence.
SCADA alarm flood
Thresholds, delays, chattering sensors, unstable links, alarms during normal transitions.
Classic commercial mistakes
No spare I/O; 24 V supply at exact calculated load; no surge protection; VFD on weak supply without line reactor then blamed for trips; safety in standard PLC logic because it was “easier”; HMI/PLC on the office flat network; undocumented unmanaged ring; no program backup/revision control; no time sync so three controllers’ logs cannot merge.
Frequently asked questions
Is a PLC the same as a PC?
No — industrial scan/control focus, environmental design and deterministic behaviour differ from general-purpose PCs.
Can SCADA replace the PLC?
No for real-time machine/process control — SCADA supervises; the PLC (or designated controller) normally runs the loops.
Does every machine need both HMI and SCADA?
No — match scope to the operation.
Does a VFD always save energy?
No — best on suitable variable-torque loads; quantify against the actual profile.
Does PROFINET/EtherNet/IP guarantee interoperability?
No — verify device roles, profiles and engineering software.
Physical I/O vs network tag?
Physical uses terminals; network points come from devices over a protocol; software tags are internal. Separate them for sizing.
Can safety run in normal PLC code?
Only with an appropriate safety-rated design and components when the risk assessment requires it — not as a shortcut.
Does RAID replace SCADA backup?
No.
Talk to PSS about automation
PSS designs, installs, and maintains automation systems — PLC, HMI, drives and SCADA — from the I/O list through commissioning. Contact the PSS team to book a first site survey.
